
Selected applications
Humanoid & legged robot use cases
Engineering examples spanning humanoid and quadruped robotics in Belgium.
- 01
Humanoid robotics · health technology
Humanoid health scanning
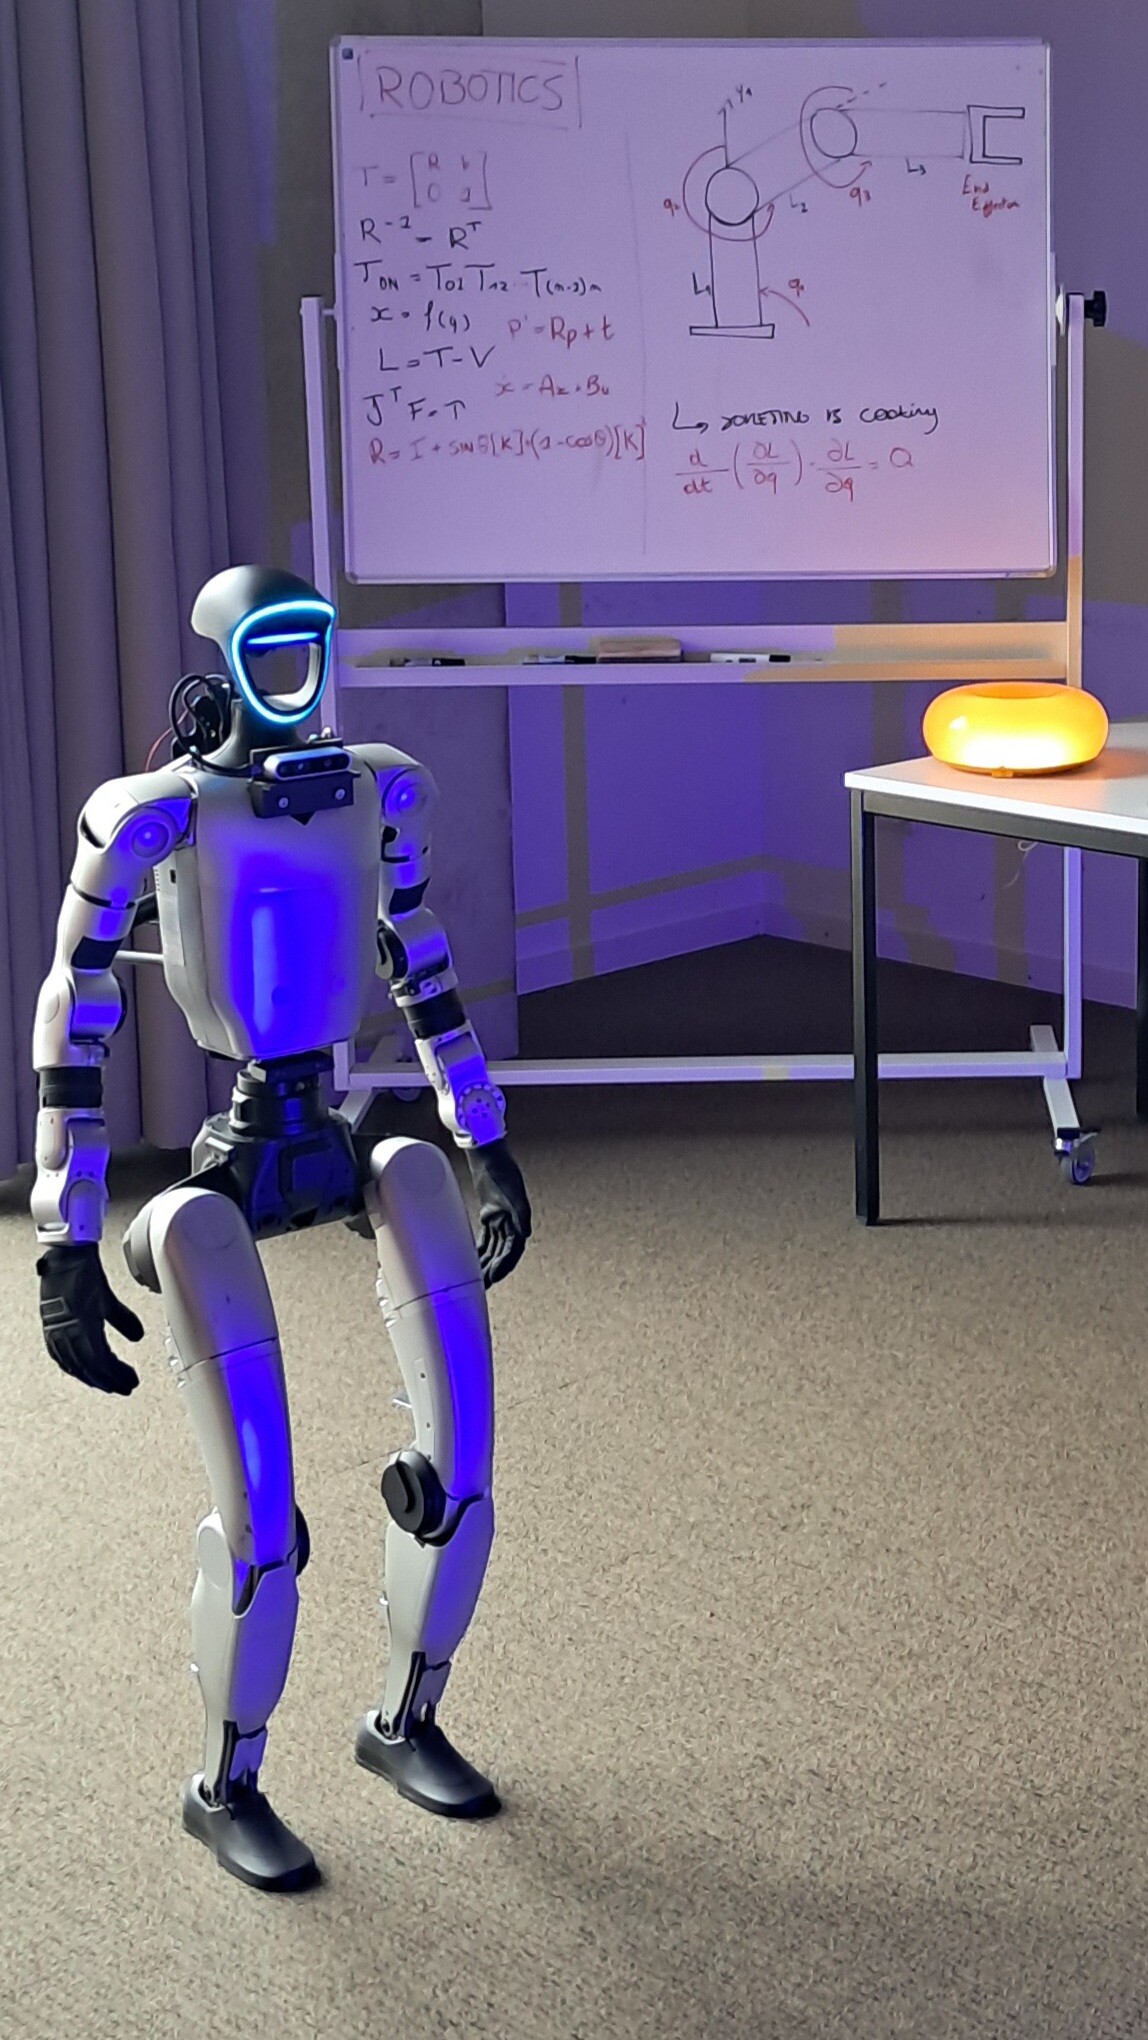
In collaboration with a startup, I explored how a humanoid platform could support health-scanning workflows. I programmed the Unitree G1 humanoid, including locomotion, behaviour control with speech, and integration of the forward-facing camera. The result was a successful proof of concept with a dashboard for controlling the robot, triggering a health scan, and communicating the results verbally to the user. The client only needed to provide the API endpoint used by the camera stream to call its existing health-analysis software stack.
Tech stack
- Robot network setup
- ROS 2
- Locomotion control
- 02
Quadruped robotics · sensor integration
Custom sensor integration on a quadruped robot (PhD)
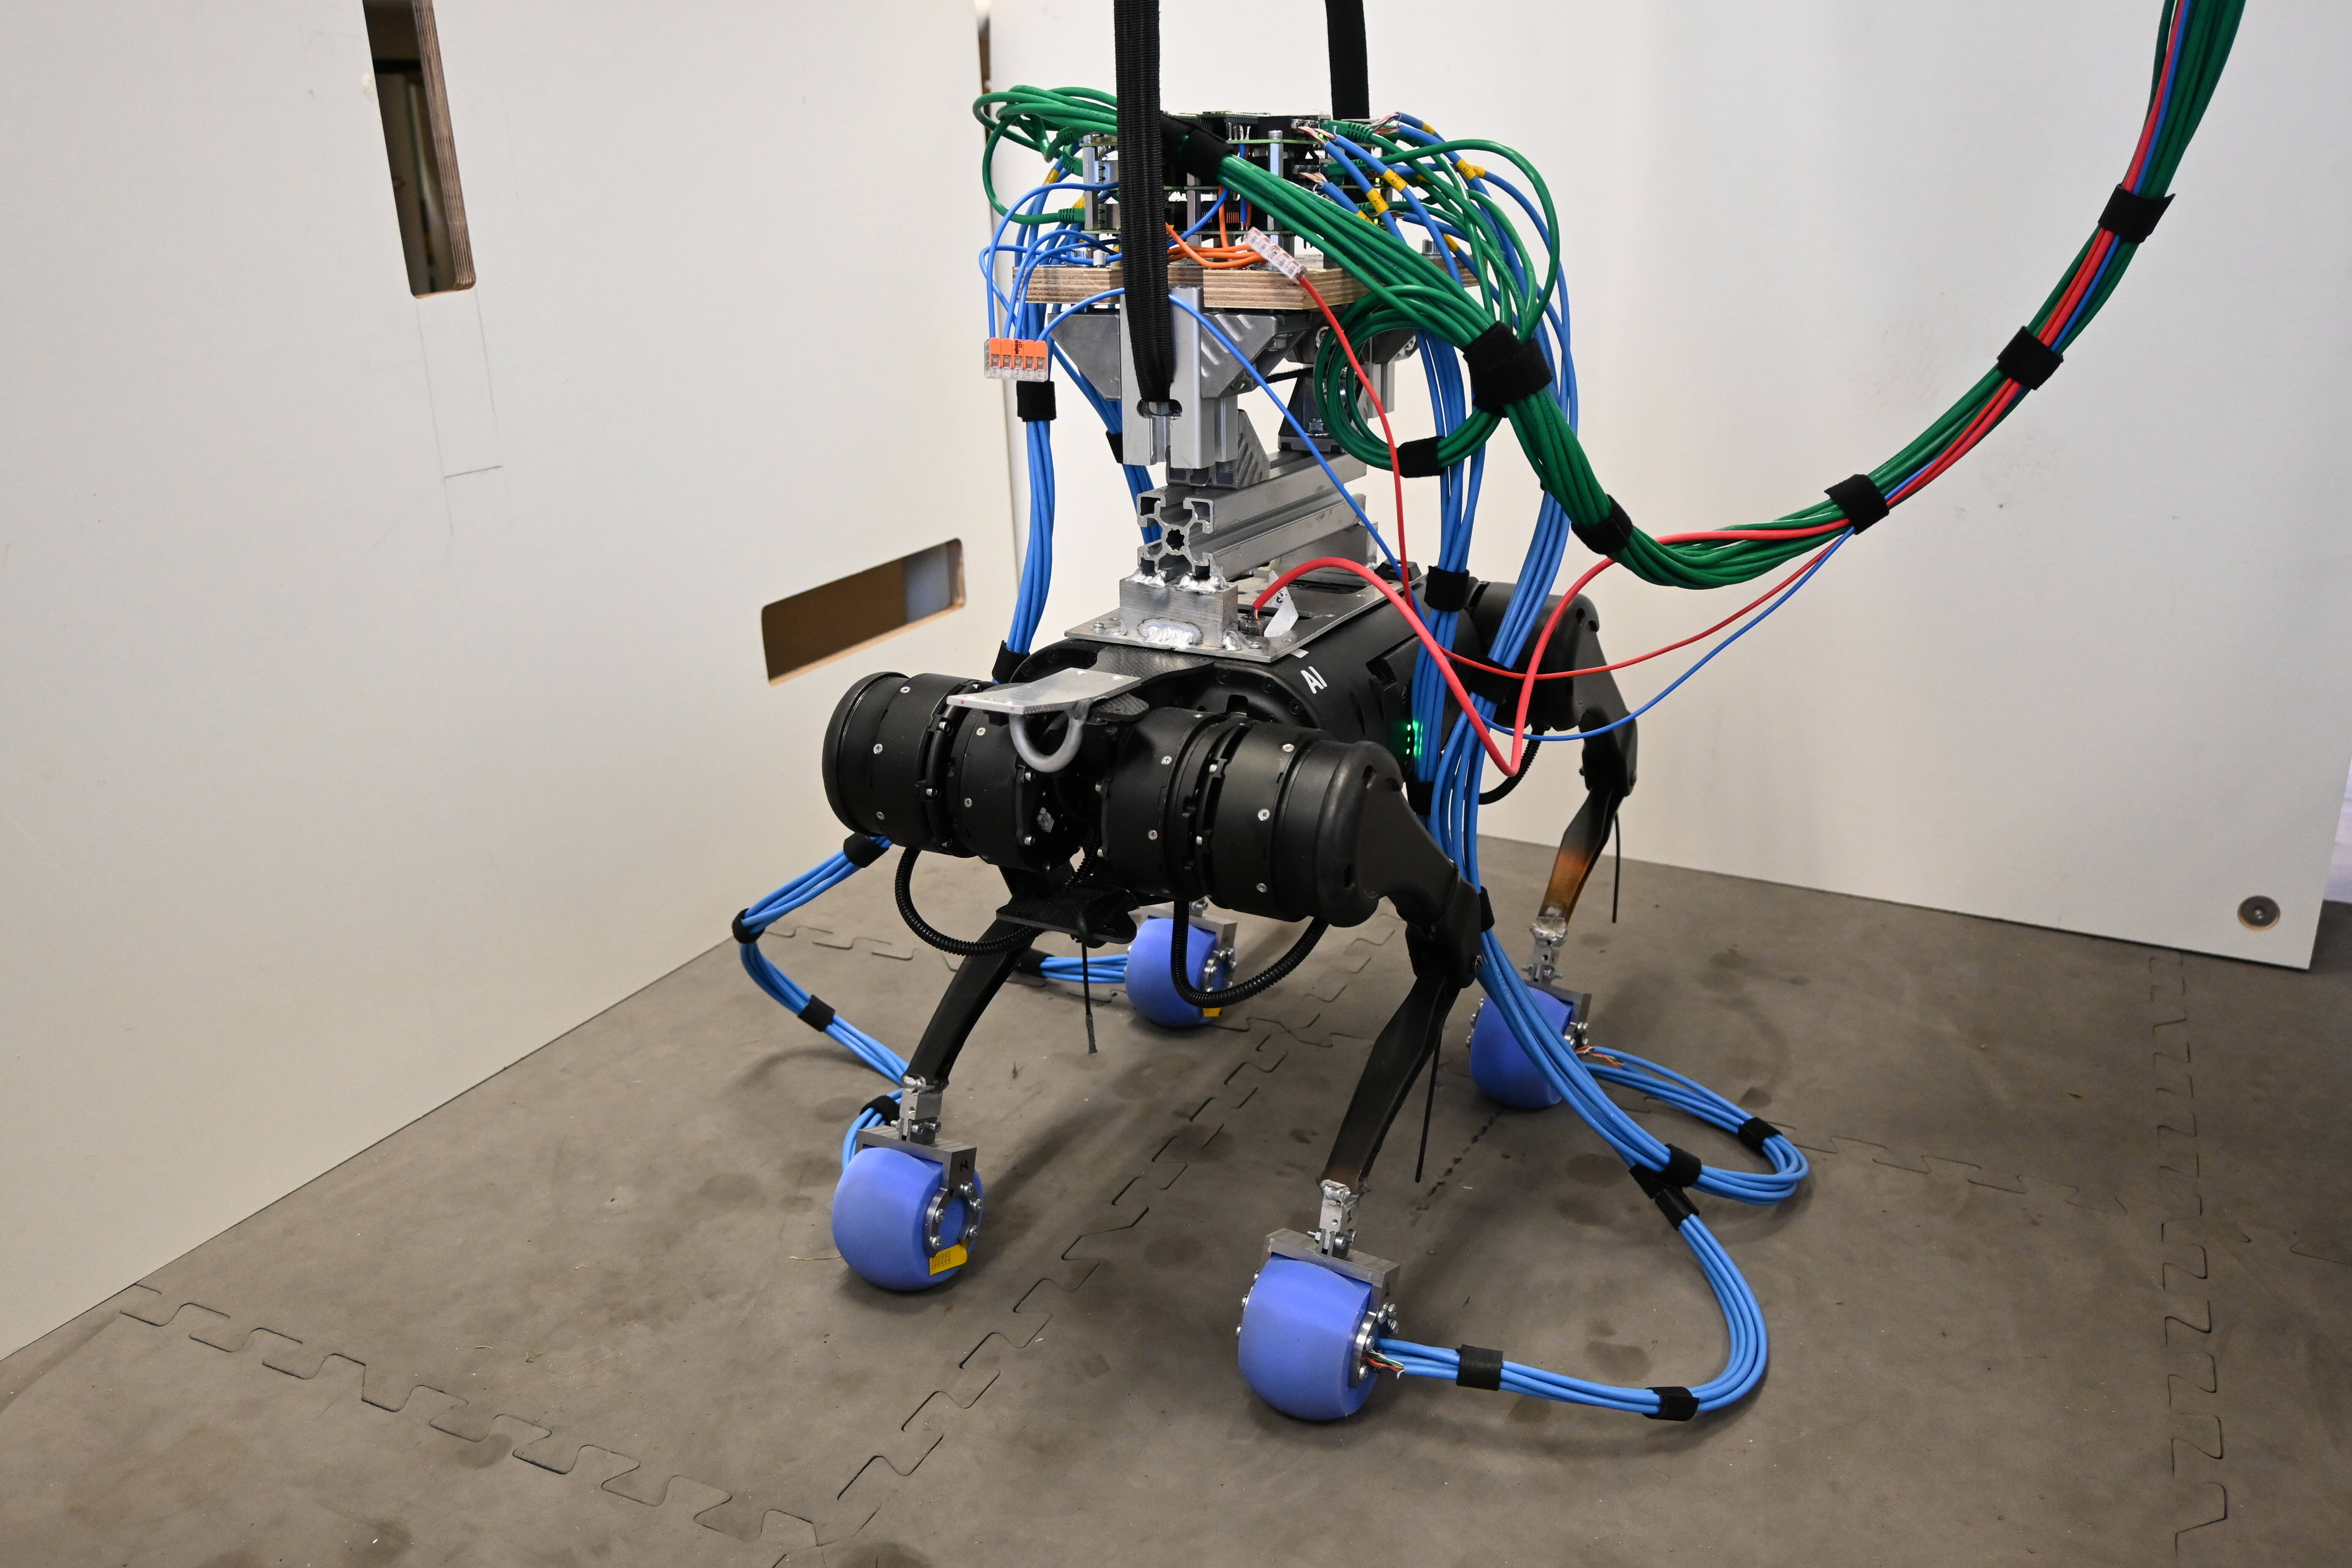
During my PhD, I equipped the Unitree Go1 with custom tactile sensor feet. Tactile sensing remains underused in robotics because of limited standardization and robustness. I investigated techniques for embedding barometric pressure sensors in a soft elastomer. These tactile-aware feet enabled the legged robot to sense the terrain and improve its locomotion.
Tech stack
- Tactile sensors
- Embedded controllers
- Robot network setup
- 03
Humanoid robotics · autonomy
Autonomous navigation for a humanoid
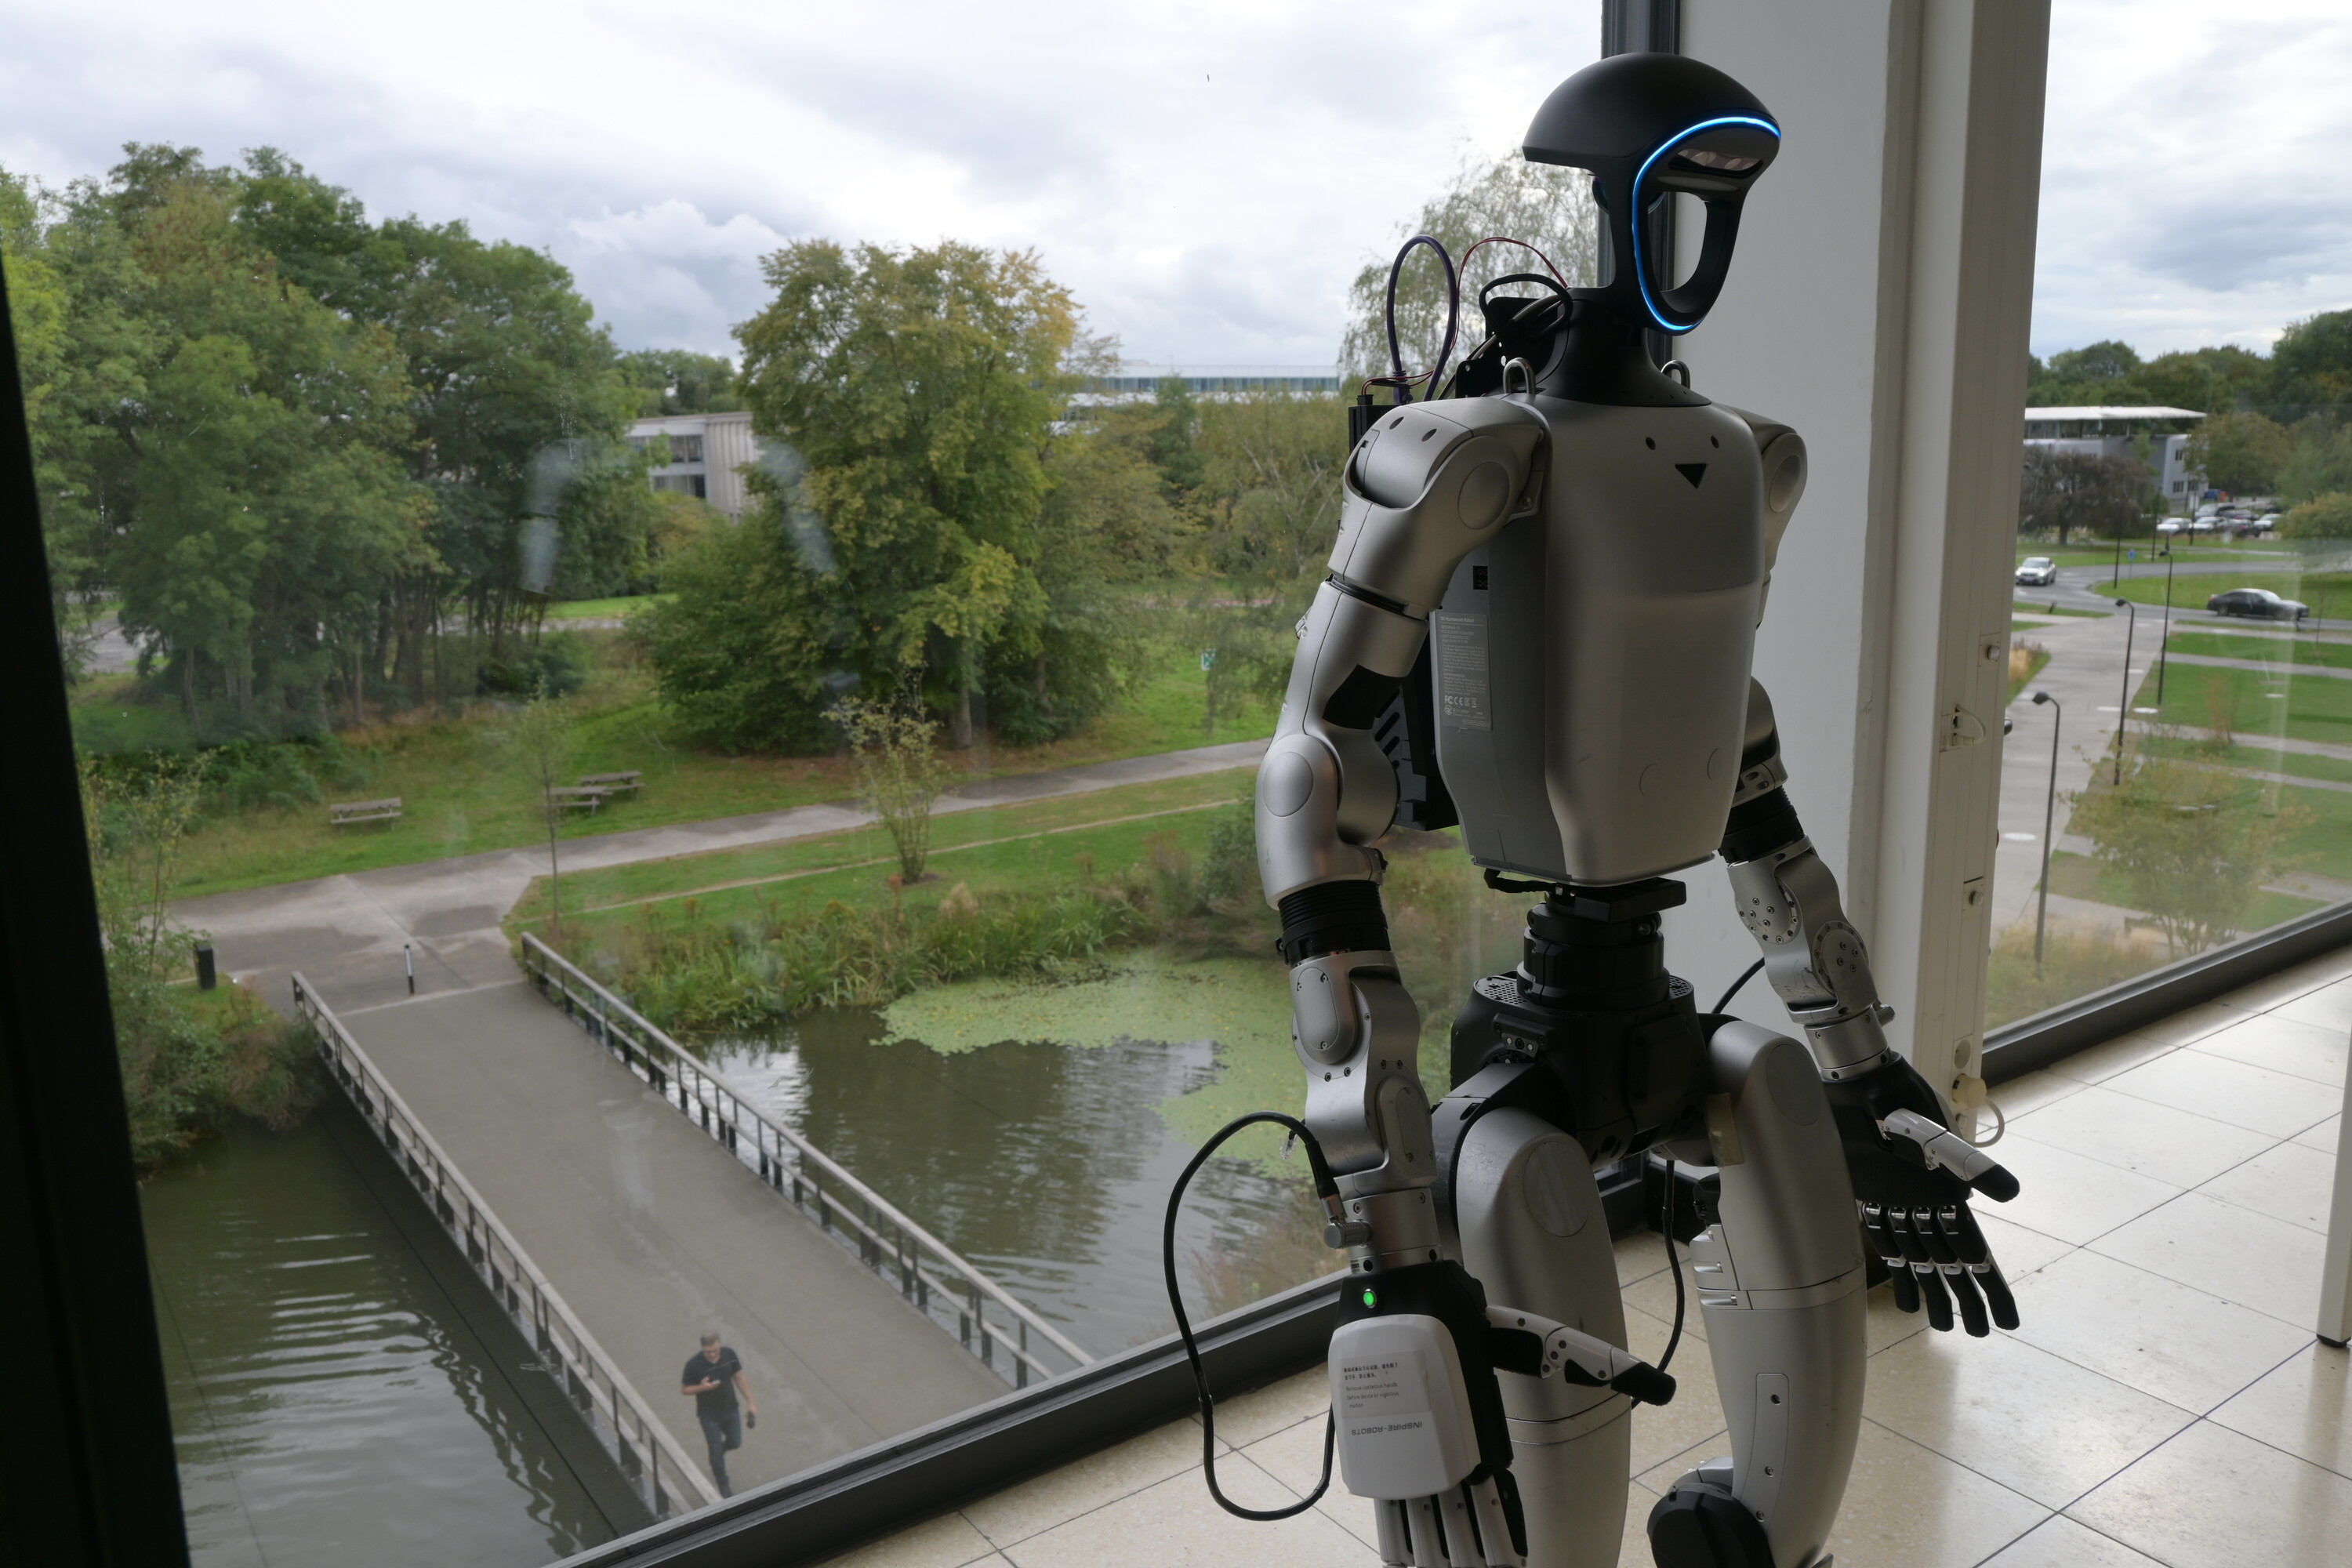
An ongoing effort to develop the autonomous navigation capabilities required for a humanoid robot to move through environments with dynamic obstacles, including voice commands and basic manipulation.
Tech stack
- Humanoid
- Human–robot interaction
- Agentic control


Evaluating a related application?
Discuss the deployment